Lane Runner version 0.9
C++17 · SDL2 · WebAssembly
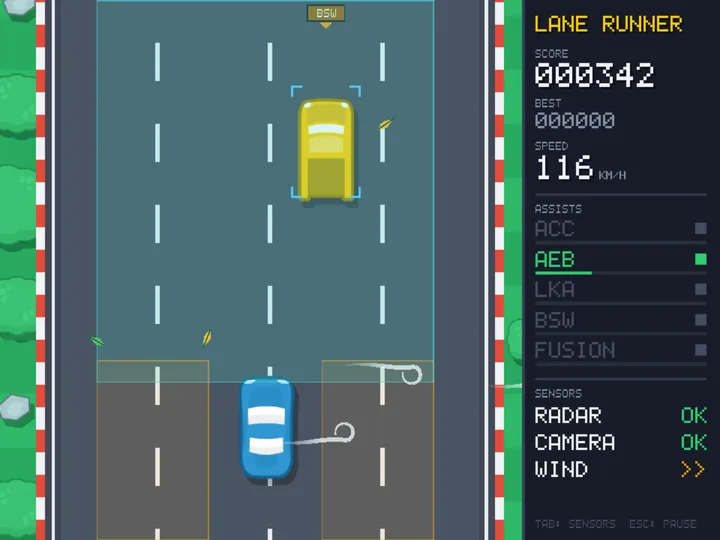
A top-down highway arcade game built around a small driver-assistance stack. Simulated sensors produce object lists, a fusion step combines them, assist functions compute requests, and arbiters decide what reaches the car. The logic runs in a fixed 20 ms cycle and is unit-tested without SDL.
- Front radar, two rear radars and a front camera behind one sensor interface. Radar ghosts under bridges, the camera is blinded by fog and tunnel glare.
- Adaptive cruise control (speed and gap PID), emergency braking by time-to-collision stages, lane keeping, blind-spot warning.
- Traffic uses IDM car following and MOBIL lane changes, with driver profiles and reaction times.
- The same code runs on Windows, Linux, a handheld console and, compiled with Emscripten, in this browser.